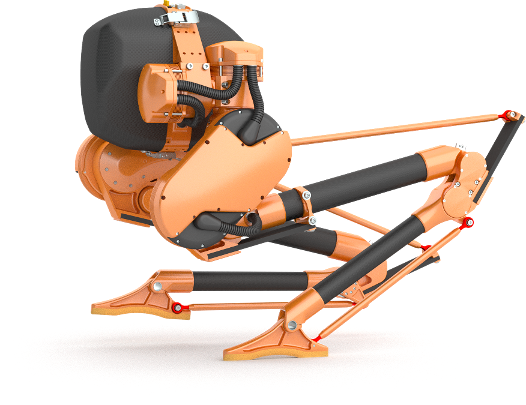
Impact-Absorbing Feet for the Cassie Bipedal Robot
Oregon State University · Dynamic Robotics Laboratory
- Role
- Undergraduate researcher (NSF-sponsored). Designed, fabricated, and tested the new feet.
- Advisor
- Prof. Jonathan Hurst
- Results
- Peak impact force reduced by over 47%, time to peak force increased by over 600%, and overall step impact reduced by over 90%
- Tools & techniques
- Silicone and foam manufacturing, material characterization, force-plate testing, and designing within the constraints of an existing control system.
The original foot (left) compared with the new foot (right).
Cassie is a bipedal robot with quiet actuators, but its hard feet slammed into the ground with every step. The impacts were loud, stressed the robot’s mechanical parts, and made it less safe to work around people. I designed new feet from silicones and foams that absorb those impacts without disrupting Cassie’s existing balance control. The best design, a silicone honeycomb with foam inserts, reduced peak impact force by over 47%, increased the time to peak force by over 600%, and reduced the overall impact of each step by over 90%, all with no changes to the controller.
Design Constraints
At the time, Cassie’s locomotion controller did not include velocity matching, so each foot hit the ground with the full force of the motors. The controller also relied on stiff feet for accurate balance. The new feet therefore had to be compliant enough to absorb the impact of walking, yet stiff enough not to interfere with the balance algorithm.
Design Methodology
I explored foot designs across two design spaces, geometry and material. The geometries included cones, diamonds, and honeycombs. The materials included silicones, foams, and the patented gel used in Purple mattresses. Each design was tested on a force plate with a simulated walking gait to measure peak force and time to peak force, and the top designs were then tested on Cassie itself while standing and walking to make sure the controls were not affected.
Geometries
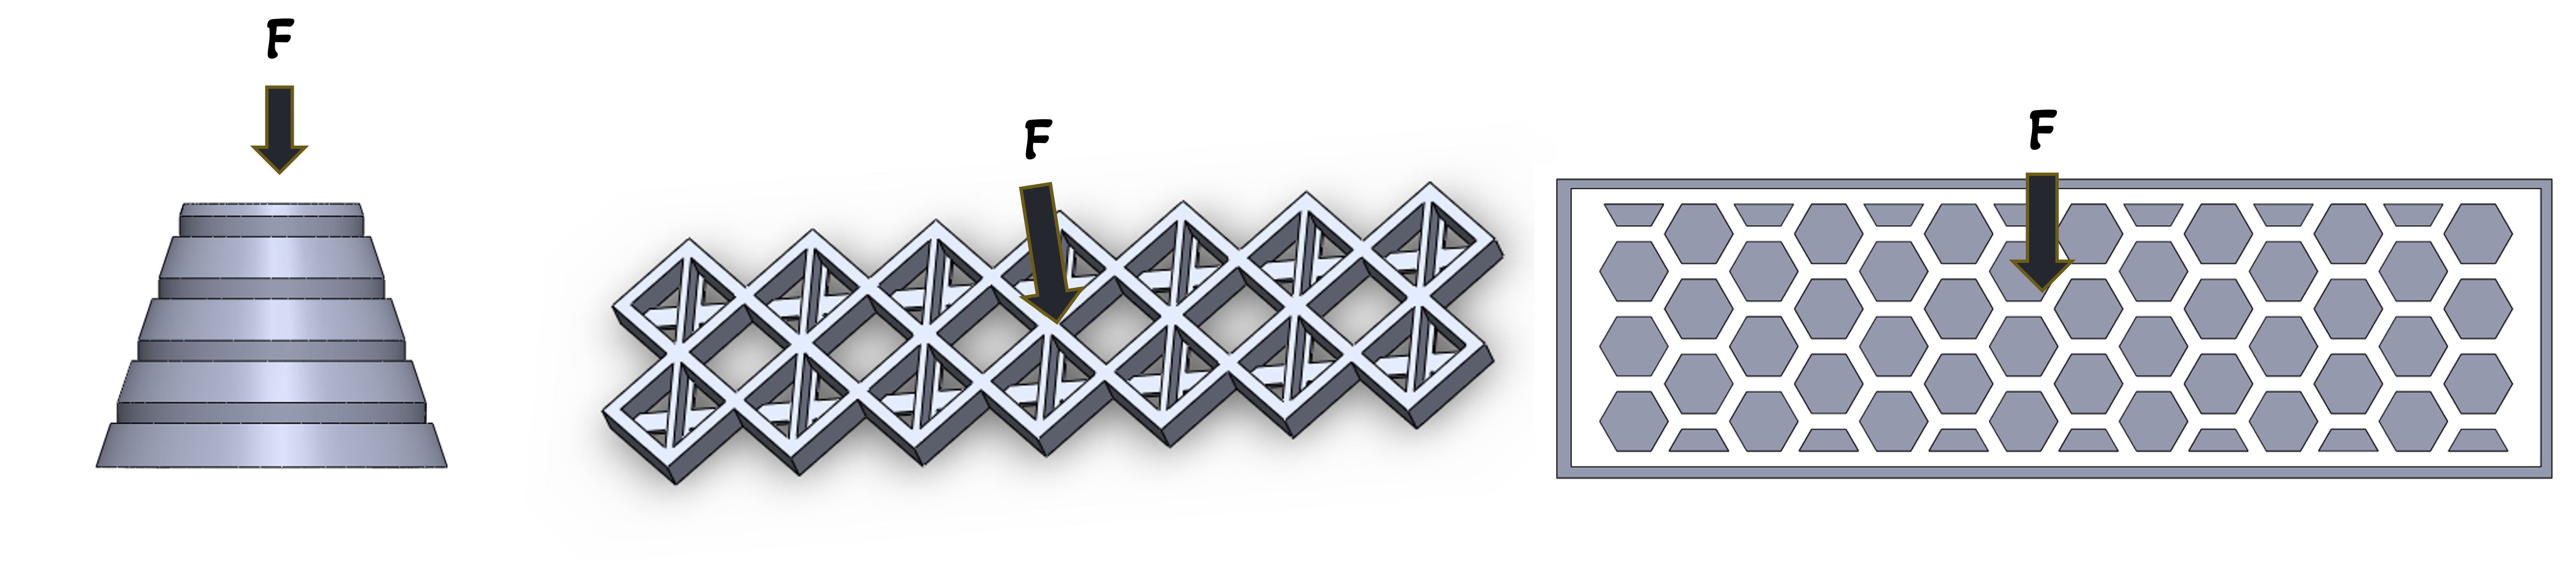 Foam was added inside each of these geometries.
- Collapsible cone (left): designed to absorb impact as the cone collapses. It proved incompatible with the robot’s control algorithm.
- Diamonds (middle): the impact-absorbing geometry used in Purple mattresses. It absorbed much of the impact and was compatible with the control algorithm.
- Hexagonal honeycomb (right): a honeycomb pattern on the bottom of the foot, tested with both horizontal loading (shown) and vertical loading, where the sides of the honeycomb absorb the impact. Horizontal loading absorbed the most, and this geometry outperformed all the others while staying compatible with the control algorithm.
Once the honeycomb collapsed, only the compliance of the material could absorb the remaining impact. To delay that collapse and reduce the impact further, I added foam between the honeycomb walls.
Materials
The feet needed both structure and compliance, so I tested a range of silicones. Durometer ratings are only a qualitative guide, so I measured each material’s compliance on a force sensor. Ecoflex 30 was chosen for its high strain under a given force, and FoamIt IV was chosen using the same criteria. All materials came from Smooth-On.
Results
Both feet provide enough stability for walking, but the new foot is much quieter and reduces wear and tear on the robot.